
Count what moves with the flange
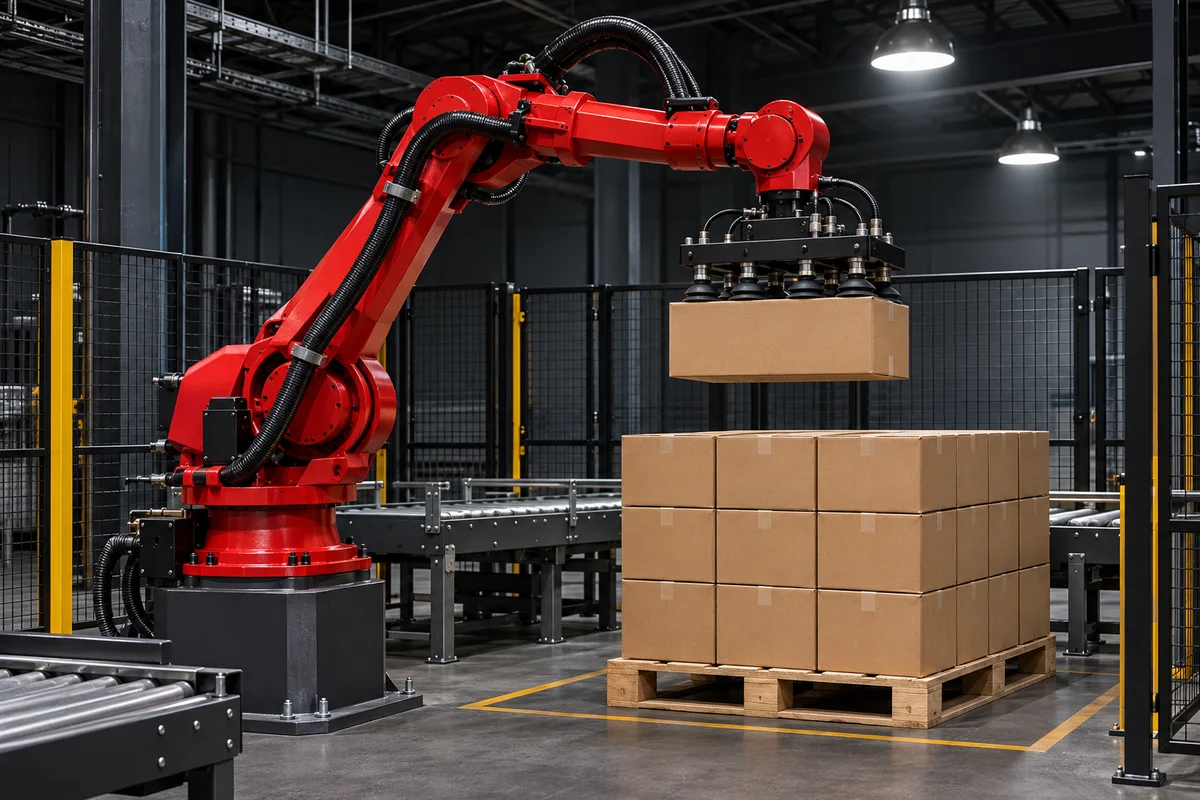
A load estimate starts with the end effector and everything it carries. Include the adapter plate, gripper, mounted sensors and the heaviest workpiece. If the cell uses interchangeable tools, describe each tool and the parts it handles separately.
Keep loaded and unloaded cases in the project brief. A carton gripper may handle several sizes and weights, and the load condition changes when it sets the carton down.
Record where the mass sits
Two tools with the same weight can put different loads on the wrist. A part held farther out from the flange changes the center of gravity and can affect the available acceleration. Tool drawings and part dimensions help the integrator evaluate those cases with the manufacturer’s load data.
Decide what to confirm in testing
Bring representative parts to the tooling review. For a vacuum tool, note the gripping surface, including holes and seams. For jaws, note where the part can be contacted and how much variation to expect. Agree on how the cell will confirm a successful grip and handle a missing part before the test.